Dhanush Penmetsa

I'm a PhD student at the CNRS-AIST Joint Robotics Laboratory (JRL) in Japan, where I'm advised by Prof. Fumio Kanehiro and Dr. Iori Kumagai. I'm supported by the MEXT Scholarship and the JST SPRING Fellowship.
Before this, I did my MS in Electrical Engineering at the University of Southern California, where I worked with Prof. Satyandra K. Gupta on pose estimation for the robotic assembly of complex parts. I did my undergrad in Electronics and Communication Engineering at Manipal Institute of Technology.

I'm happy to collaborate, so feel free to reach out by email.

Research

Currently, I'm working on combining model-based methods with scalable robot learning methods.

Previously, I worked on pose estimation for the robotic assembly of complex parts from proprioception alone, combining contact-manifold registration with deep learning.
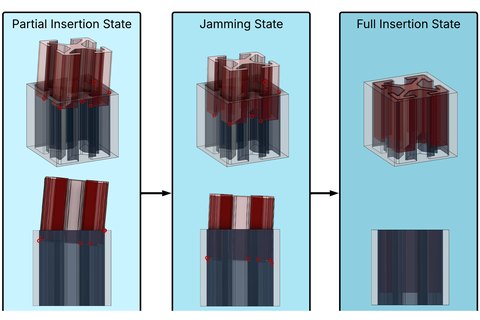
A complex peg shown in partial insertion, jamming and full insertion states
Accurate Pose Estimation Using Contact Manifold Sampling for Safe Peg-in-Hole Insertion of Complex Geometries
Abhay Negi, Omey M. Manyar, Dhanush Penmetsa, and Satyandra K. Gupta
IEEE CASE, 2025
arXiv

Estimating the pose of a part relative to its hole from contact information alone, for safe insertion of complex geometries with tight clearances.
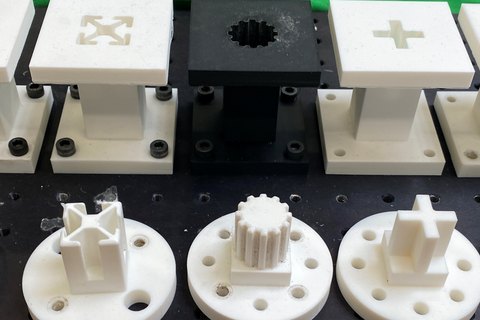
3D-printed extrusion, gear and cross holes with their matching pegs
Learning the Contact Manifold for Accurate Pose Estimation During Peg-in-Hole Insertion of Complex Geometries
Abhay Negi, Omey M. Manyar, Dhanush Penmetsa, and Satyandra K. Gupta
ICRA Contact-Rich Manipulation Workshop, 2025  (Best Paper Runner-Up)
arXiv

Estimating peg–hole pose by matching contacts from simple probing motions to a precomputed contact manifold, using a learned projection network.
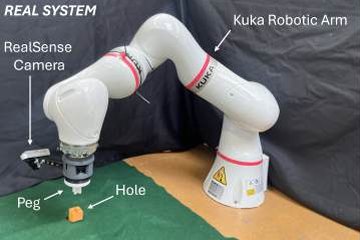
KUKA robot arm with a wrist-mounted RealSense camera, inserting a peg into a hole
Autonomous Execution of Insertion Operations in Space Assembly Tasks
Abhay Negi, Nikita Sarawgi, Dhanush Penmetsa, Hantao Ye, Omey M. Manyar, Minseok Jeon, Zachary McNulty, Siddhant Wadaskar, Ashtin K. Cheng, and Satyandra K. Gupta
AIAA SciTech Forum, 2025
paper

Vision-based pose estimation followed by compliant, impedance-controlled insertion, for robotic assembly tasks in space.

Education

University of Tsukuba
Ph.D. in Engineering, Intelligent and Mechanical Interaction Systems
Apr 2026 – present
University of Colorado Boulder
Ph.D. in Computer Science (withdrawn)
Aug 2025 – Jan 2026
University of Southern California
M.S. in Electrical Engineering
Aug 2022 – May 2024
Manipal Institute of Technology
B.Tech. in Electronics and Communication Engineering
Sep 2018 – Jun 2022

Experience

RROS Lab, University of Southern California
Research Assistant with Prof. Satyandra K. Gupta.
Apr 2023 – Jul 2025
SLURM Lab, University of Southern California
Research Assistant with Prof. Daniel Seita, working on combining reinforcement learning with differentiable trajectory optimization.
Oct 2023 – Oct 2024
RoboManipal, Manipal Institute of Technology
Student robotics team.
Sep 2018 – Sep 2021

Teaching

University of Colorado Boulder
Teaching Assistant, CSCI 2400: Computer Systems
Fall 2025

Service

Reviewer: ICRA 2027
Reviewer: ICRA 2026
Reviewer: ICRA 2024 3D Manipulation Workshop
Reviewer: ICRA 2024 Agile Robotics Workshop